Publications
119 papers from 1995 to 2026. Lab members are shown in bold. For a complete citation record, see Professor Shimada's Google Scholar profile.
2026
-
Stress-driven and user-guided Pythagorean-Hodograph print-paths for additive manufacturing
Computer-Aided Design, vol. 199, art. 104138
-
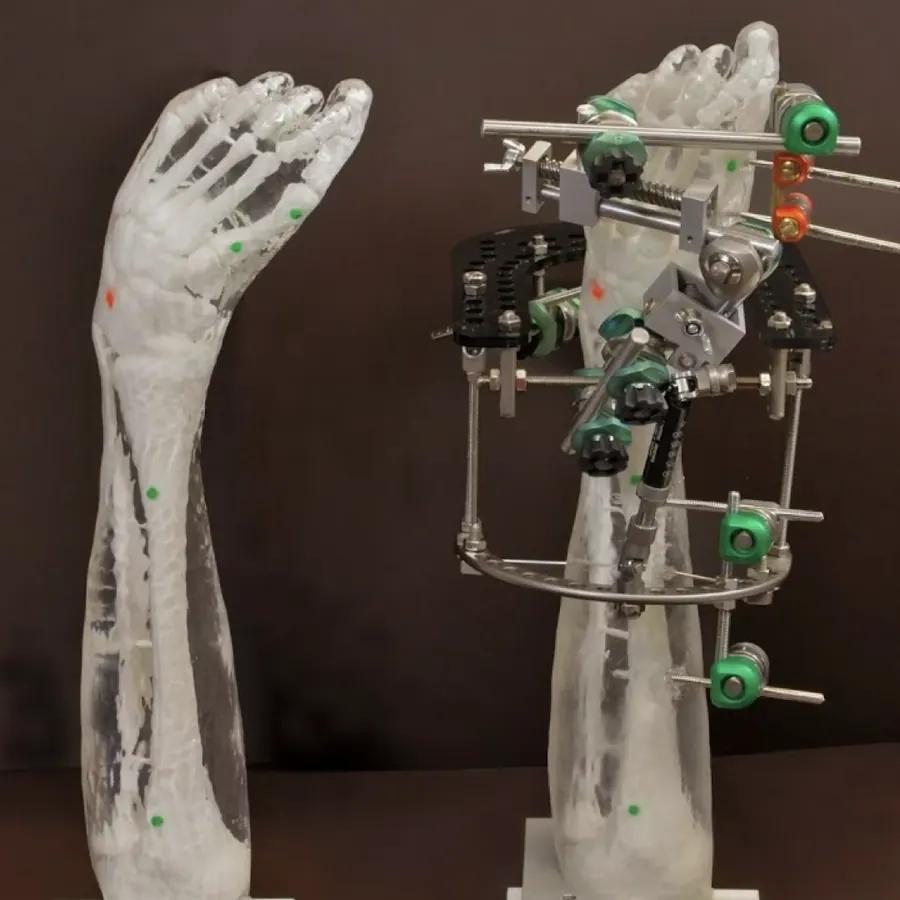
Evaluation of a Novel Educational Three-Dimensionally–Printed, Unstable, Distal Radius Fracture Model for Reduction and Splinting
Journal of the American Academy of Orthopaedic Surgeons, vol. 34, pp. e2118-e2125
-
Ortho2CAD: 3D CAD generation from orthographic drawings using vision language models
Preprint arXiv preprint
-
Analyzing and testing bimetallic additively manufactured structures for tailored thermal expansion
Rapid Prototyping Journal, vol. 32, pp. 1602-1616
-
ASIP-Planner: Adaptive Planning for UAV Surface Inspection in Partially Known Indoor Environments
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026, accepted)
-
Computational Investigation on the Combined Effect of Applied Strain and Pore Configuration on Strain Concentrators in Additively Manufactured Metals
Fatigue & Fracture of Engineering Materials & Structures, vol. 49, pp. 1656-1679
-
Material grade-based task planning for robotic limestone mining
Advanced Robotics, vol. 40, pp. 63-82
2025
-
Evaluating Tetrahedral Latticed Cubes Optimized for Additive Manufacturing Through Finite Element Analysis and Geometric Scanning Validation
3D Printing and Additive Manufacturing, vol. 12, pp. 633-646
-
Concrete Spray 3D Printing Simulator for Nozzle Trajectory Planning
IEEE Robotics and Automation Letters, vol. 10, pp. 11586-11593
-
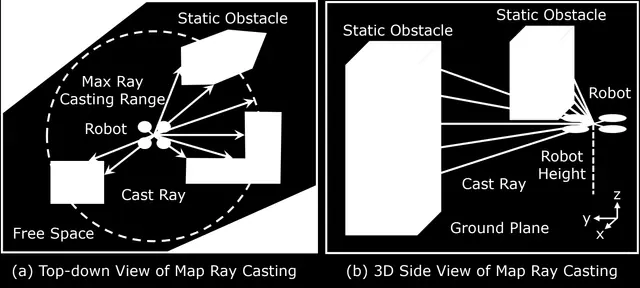
Semantic Exploration and Dense Mapping of Complex Environments Using Ground Robot With Panoramic LiDAR-Camera Fusion
IEEE Robotics and Automation Letters, vol. 10, pp. 11196-11203
-
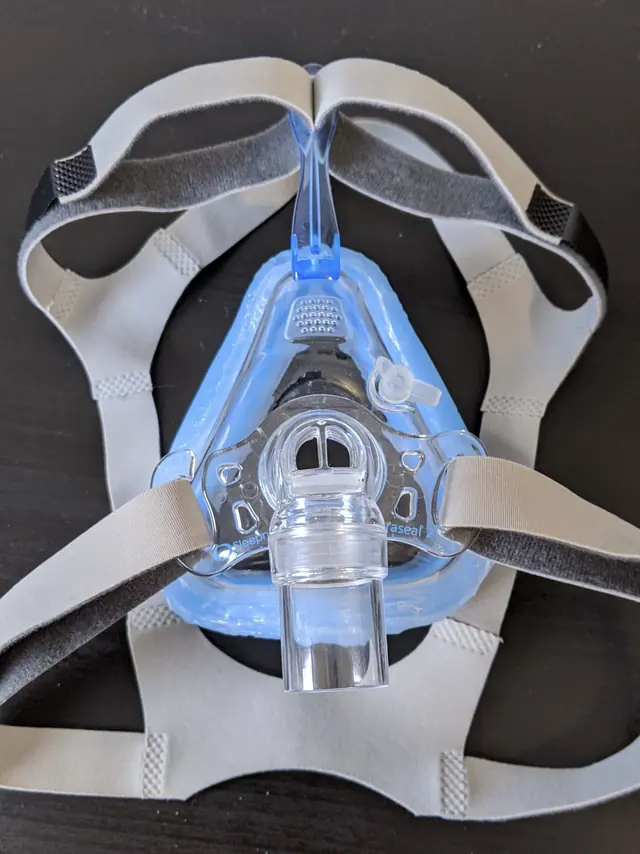
Method for evaluating the fit of custom-fit Continuous Positive Airway Pressure masks using finite element analysis
Computer Methods in Biomechanics and Biomedical Engineering, vol. 28, pp. 1800-1817
-
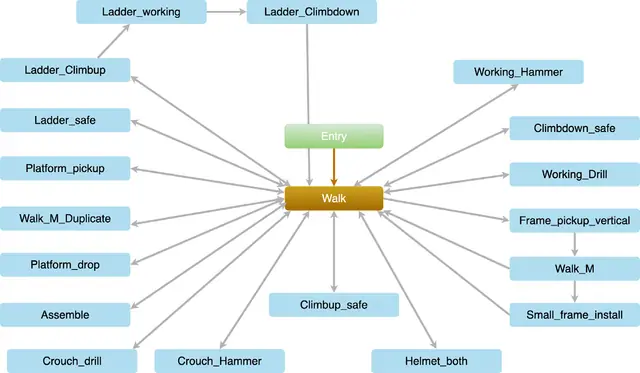
Safe-Construct: Redefining Construction Safety Violation Recognition as 3D Multi-View Engagement Task
IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW), pp. 5811-5820
-
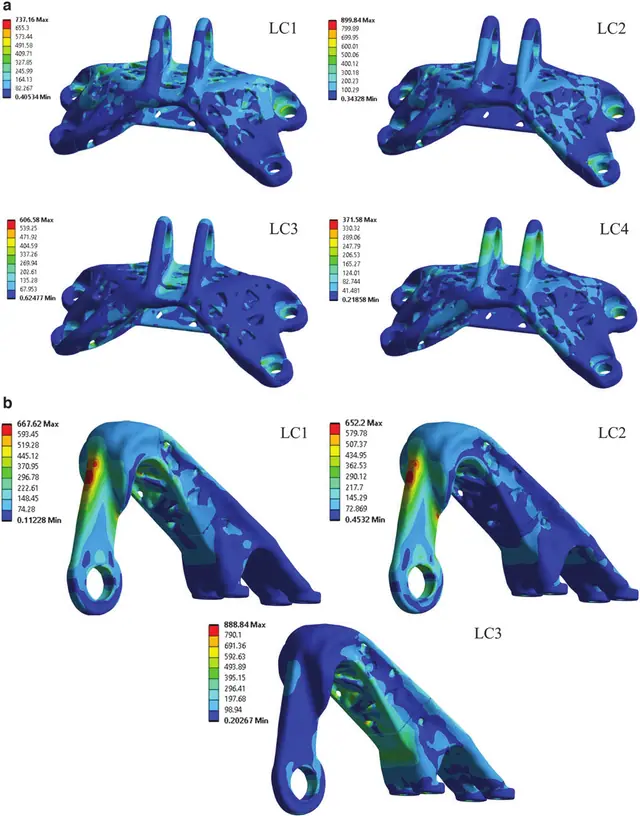
Redesigning Aerospace Components Using a Coupled Topology Optimization and Lattice Generation Approach
3D Printing and Additive Manufacturing, vol. 12, pp. 223-238
-
Intent Prediction-Driven Model Predictive Control for UAV Planning and Navigation in Dynamic Environments
IEEE Robotics and Automation Letters, vol. 10, pp. 4946-4953
-
NavRL: Learning Safe Flight in Dynamic Environments
IEEE Robotics and Automation Letters, vol. 10, pp. 3668-3675
-
Learning 3D human–object interaction graphs from transferable context knowledge for construction monitoring
Computers in Industry, vol. 164, art. 104171
-
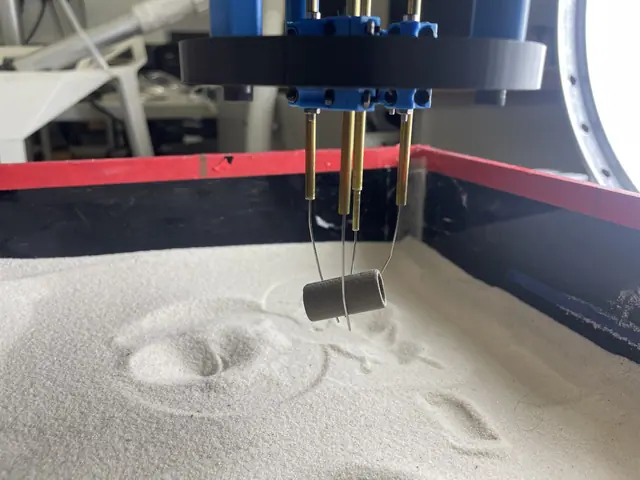
Novel Wire Gripper for Robotics Picking of Small Green Parts From Powder Bed of Binder Jet Metal Additive Manufacturing
IEEE Access, vol. 13, pp. 110821-110827



2024
-
Development of a Novel Soft Tissue Measurement Device for Individualized Finite Element Modeling in Custom-Fit CPAP Mask Evaluation
Annals of Biomedical Engineering, vol. 52, pp. 3184-3195
-
Multi-Class Entity Classification on Rasterized Engineering Drawings Using Graph Learning
ASME International Mechanical Engineering Congress and Exposition (IMECE), pp. V002T03A096
-
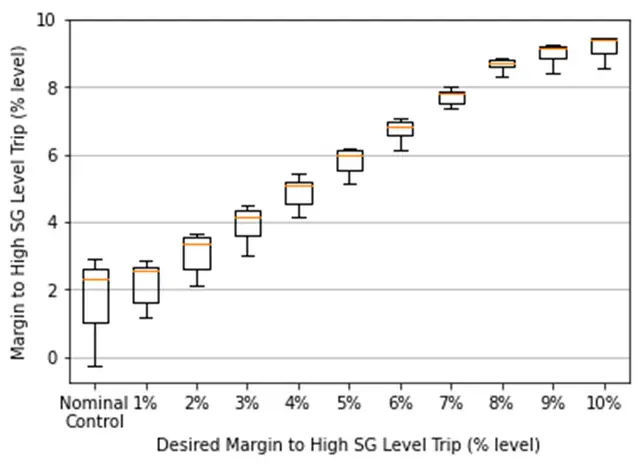
Determination of Gain Scheduling Parameters for Loss of a Feedwater Pump Transient Mitigation Using Neural Networks
Nuclear Technology, vol. 210, pp. 2204-2214
-
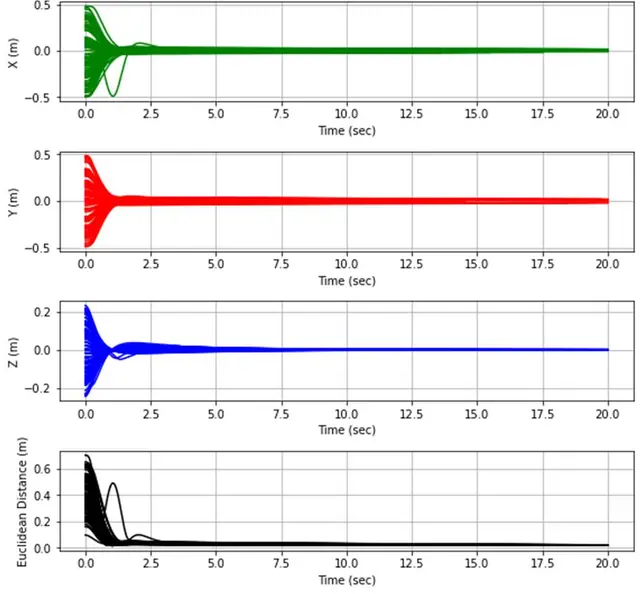
Wind Disturbance Rejection for UAVs Using Controller Settings Determined by Neural Networks
IEEE International Conference on Automatic Control and Intelligent Systems (I2CACIS), pp. 1-5
-
Heuristic-based Incremental Probabilistic Roadmap for Efficient UAV Exploration in Dynamic Environments
IEEE International Conference on Robotics and Automation (ICRA), pp. 11832-11838
-
Quadcopter Trajectory Time Minimization and Robust Collision Avoidance via Optimal Time Allocation
IEEE International Conference on Robotics and Automation (ICRA), pp. 16531-16537
-
Applying Reinforcement Learning to PID Flight Control of a Quadrotor Drone to Mitigate Wind Disturbances
International Conference on Automation, Robotics and Applications (ICARA), pp. 285-293
-
A Data Augmentation Method for Data-Driven Component Segmentation of Engineering Drawings
Journal of Computing and Information Science in Engineering, vol. 24, art. 011001
-
Onboard Dynamic-Object Detection and Tracking for Autonomous Robot Navigation With RGB-D Camera
IEEE Robotics and Automation Letters, vol. 9, pp. 651-658


2023
-
Optimization Framework for Global Path Planning and Local Motion Planning for Robotic Welding of Multiple Large Industrial Parts
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1-8
-
A Vision-Based Autonomous UAV Inspection Framework for Unknown Tunnel Construction Sites With Dynamic Obstacles
IEEE Robotics and Automation Letters, vol. 8, pp. 4983-4990
-
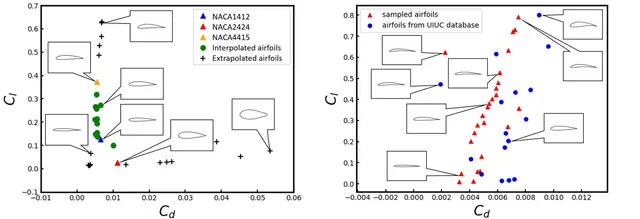
Airfoil GAN: encoding and synthesizing airfoils for aerodynamic shape optimization
Journal of Computational Design and Engineering, vol. 10, pp. 1350-1362
-
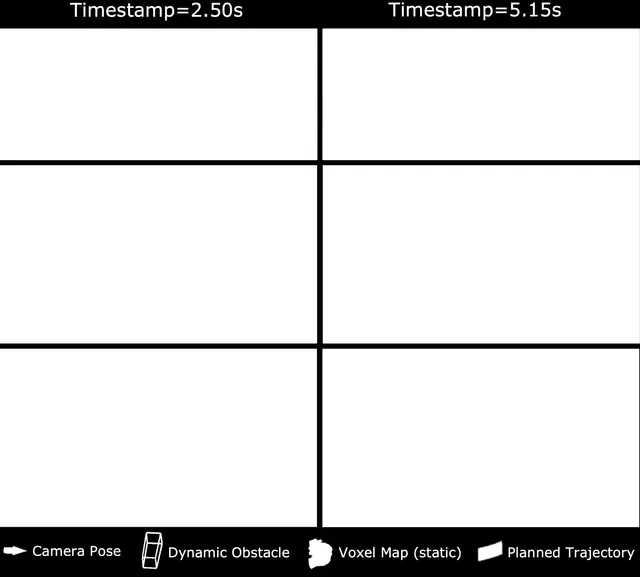
A real-time dynamic obstacle tracking and mapping system for UAV navigation and collision avoidance with an RGB-D camera
IEEE International Conference on Robotics and Automation (ICRA), pp. 10645-10651
-
Vision-aided UAV Navigation and Dynamic Obstacle Avoidance using Gradient-based B-spline Trajectory Optimization
IEEE International Conference on Robotics and Automation (ICRA), pp. 1214-1220
-
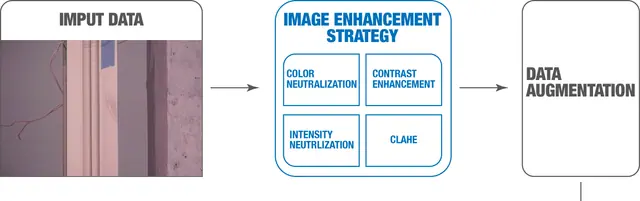
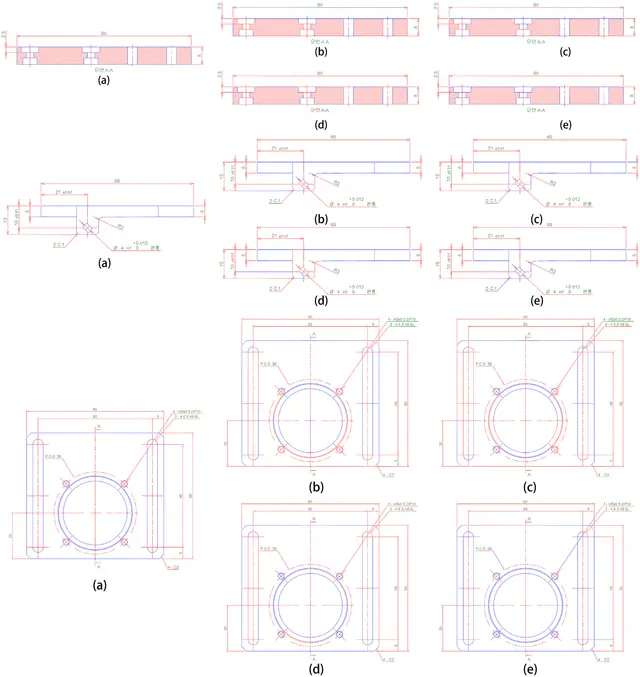
Component segmentation of engineering drawings using Graph Convolutional Networks
Computers in Industry, vol. 147, art. 103885

2022
-
Data-driven Analysis of Engineering Drawings Using Component-based Graphs
Thesis Ph.D. Dissertation, Department of Mechanical Engineering, Carnegie Mellon University
-
Graph neural network-enabled manufacturing method classification from engineering drawings
Computers in Industry, vol. 142, art. 103697
-
Robotic Depowdering for Additive Manufacturing Via Pose Tracking
IEEE Robotics and Automation Letters, vol. 7, pp. 10770-10777
-
Three-Dimensional Ship Hull Encoding and Optimization via Deep Neural Networks
Journal of Mechanical Design, vol. 144, art. 101701
-
Data Augmentation of Engineering Drawings for Data-Driven Component Segmentation
ASME International Design Engineering Technical Conferences and Computers and Information in Engineering Conference (IDETC/CIE), pp. V03AT03A016
-
SAGA-net: shape-assisted graph attention neural network for real-time pointcloud completion
ACM SIGAPP Applied Computing Review, vol. 22, pp. 21-33
-
DPMPC-Planner: A real-time UAV trajectory planning framework for complex static environments with dynamic obstacles
IEEE International Conference on Robotics and Automation (ICRA), pp. 250-256
-
SAGA-Net: efficient pointcloud completion with shape-assisted graph attention neural network
ACM/SIGAPP Symposium on Applied Computing (SAC), pp. 569-576
2021
-
Moldable Mask: A Reusable, Hot Water Moldable, Additively Manufactured Mask to Be Used as an N95 Alternative
Materials, vol. 14, pp. 7082
-
Motion Planning for Kinematically Redundant Mobile Manipulators with Genetic Algorithm, Pose Interpolation, and Inverse Kinematics
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1167-1174
-
Assessing Tetrahedral Lattice Parameters for Engineering Applications Through Finite Element Analysis
3D Printing and Additive Manufacturing, vol. 8, pp. 238-252
-
Design and Fabrication of Custom-Fit BiPAP and CPAP Masks Using Three-Dimensional Imaging and Three-Dimensional Printing Techniques
Journal of Medical Devices, vol. 15, art. 024502
-
High-Fidelity Wrist Fracture Phantom as a Training Tool to Develop Competency in Orthopaedic Surgical Trainees
JAAOS: Global Research and Reviews, vol. 5, pp. e20.00224-8
-
Autonomous UAV Exploration of Dynamic Environments Via Incremental Sampling and Probabilistic Roadmap
IEEE Robotics and Automation Letters, vol. 6, pp. 2729-2736

2020
-
Coordinated Aerial-Ground Robot Exploration via Monte-Carlo View Quality Rendering
Preprint arXiv preprint
-
Multi-UAV Coverage Path Planning for the Inspection of Large and Complex Structures
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1480-1486
-
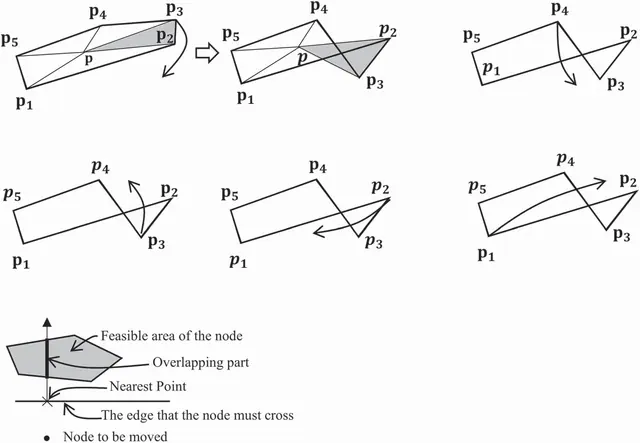
Improved Feasible-Set Method for Removing Mesh Inversion
Journal of Computing and Information Science in Engineering, vol. 20, art. 041011
-
Landing A Mobile Robot Safely from Tall Walls Using Manipulator Motion Generated from Reinforcement Learning
IEEE International Conference on Automation Science and Engineering (CASE), pp. 8-15
-
Inventory Tracking for Unstructured Environments via Probabilistic Reasoning
Logistics, vol. 4, pp. 16
-
Robotic Exploration of Unknown 2D Environment Using a Frontier-based Automatic-Differentiable Information Gain Measure
IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), pp. 1497-1503
-
A Deep Reinforcement Learning Approach for Global Routing
Journal of Mechanical Design, vol. 142, art. 061701
-
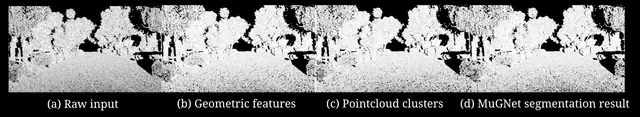
MuGNet: Multi-Resolution Graph Neural Network for Segmenting Large-Scale Pointclouds.
Conference on Robot Learning, pp. 873-882
2019
-
Constrained Heterogeneous Vehicle Path Planning for Large-area Coverage
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 4113-4120
-
Coverage Path Planning using Path Primitive Sampling and Primitive Coverage Graph for Visual Inspection
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1472-1479
-
Tracking Tagged Inventory in Unstructured Environments through Probabilistic Dependency Graphs
Logistics, vol. 3, pp. 21
-
3D Shape Synthesis for Conceptual Design and Optimization Using Variational Autoencoders
ASME International Design Engineering Technical Conferences and Computers and Information in Engineering Conference (IDETC/CIE), pp. V02AT03A017
-
Designing a Mobility Solution for Fully Autonomous Welding of Double-Hull Blocks
Journal of Mechanisms and Robotics, vol. 11, art. 045002
-
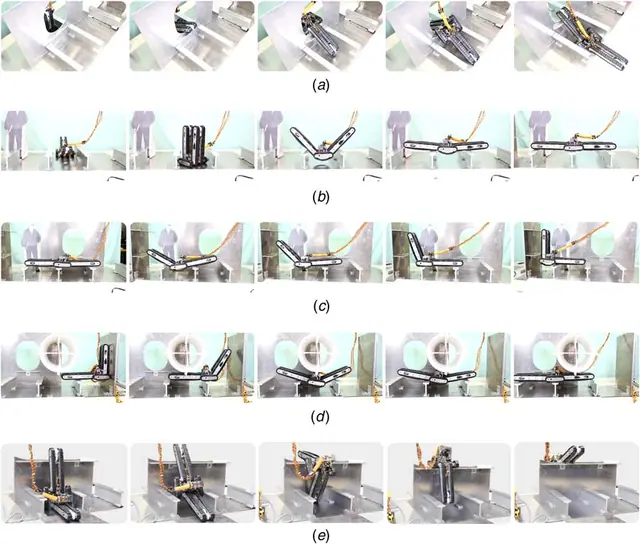
Compact Two Degrees-of-Freedom External Fixator System for Correction of Persistent Clubfoot Deformity
Journal of Medical Devices, vol. 13, art. 021005


2018
-
Material characterization and selection for 3D-printed spine models
3D Printing in Medicine, vol. 4, pp. 8
-
Heterogeneous Vehicles Routing for Water Canal Damage Assessment
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 2375-2382
-
Custom-Fit Three-Dimensional-Printed BiPAP Mask to Improve Compliance in Patients Requiring Long-Term Noninvasive Ventilatory Support
Journal of Medical Devices, vol. 12, art. 031003
-
Robot Model Learning with Gaussian Process Mixture Model
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1263-1268
-
Semi-Automatic Snore Detection in Polysomnography based on Hierarchical Clustering
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1116-1122
-
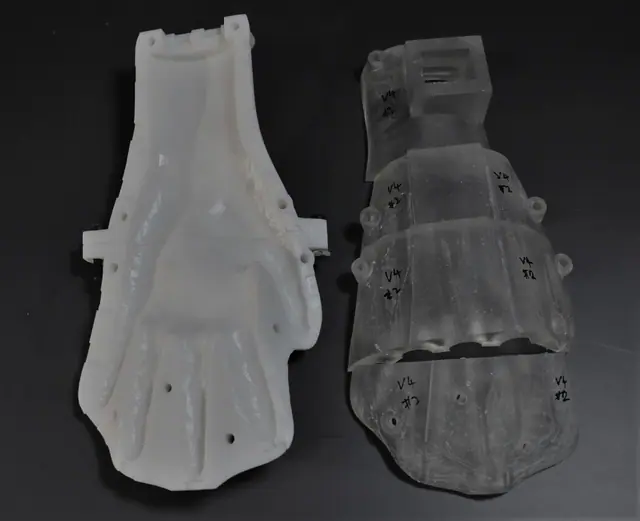
A High-fidelity Tactile Hand Simulator as a Training Tool to Develop Competency in Percutaneous Pinning in Residents
JAAOS: Global Research and Reviews, vol. 2, pp. e028
-
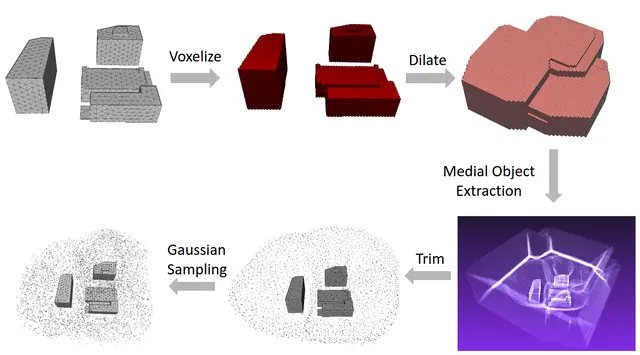
Model-based view planning for building inspection and surveillance using voxel dilation, Medial Objects, and Random-Key Genetic Algorithm
Journal of Computational Design and Engineering, vol. 5, pp. 337-347
-
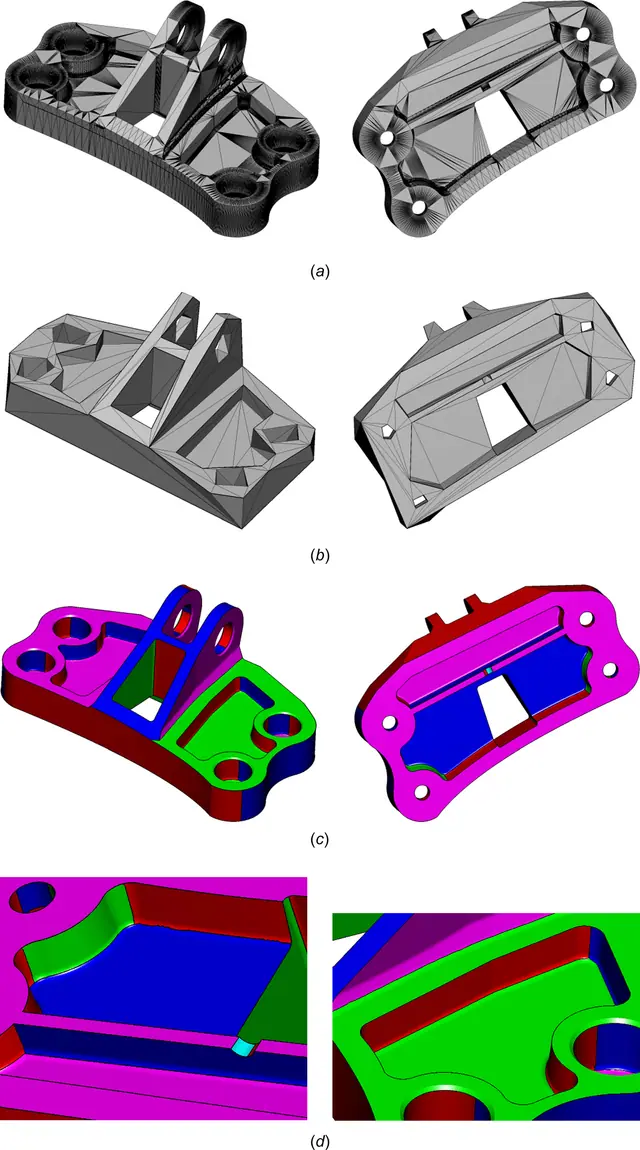
Feature Edge Extraction Via Angle-Based Edge Collapsing and Recovery
Journal of Computing and Information Science in Engineering, vol. 18, art. 021001
-
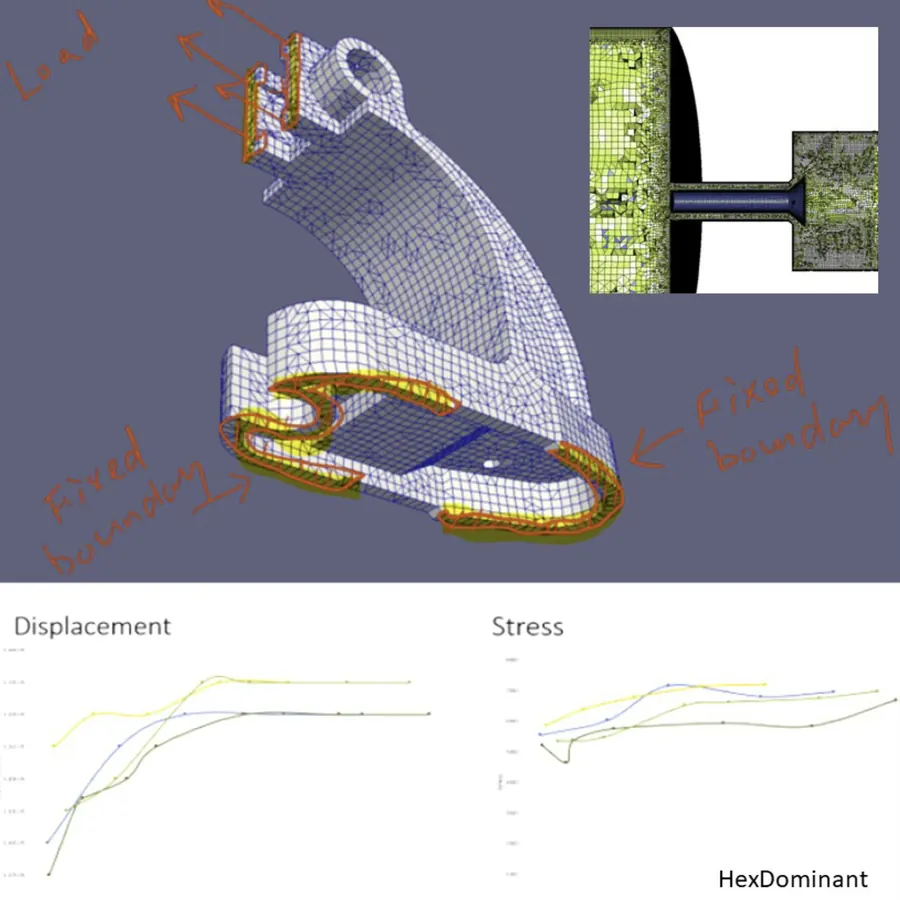
Automatic Hex-Dominant Mesh Generation for Complex Flow Configurations
SAE International Journal of Engines, vol. 11, pp. 615-624
-
A Computational Framework for Automatic Online Path Generation of Robotic Inspection Tasks via Coverage Planning and Reinforcement Learning
IEEE Access, vol. 6, pp. 54854-54864
-
Multi-objective optimization and scenario-based robustness analysis of the MoneyMaker Hip Pump
Development Engineering, vol. 3, pp. 23-33
2017
-
Evaluation of user-guided semi-automatic decomposition tool for hexahedral mesh generation
Journal of Computational Design and Engineering, vol. 4, pp. 330-338
-
Framework for automatic generation of facades on free-form surfaces
Frontiers of Architectural Research, vol. 6, pp. 273-289
-
International Innovation Design School for Enhancing the Ability of Designing Future Products
Proceedings of the JSPE Autumn Meeting (Japan Society for Precision Engineering)
-
Sampling-based coverage motion planning for industrial inspection application with redundant robotic system
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 5211-5218
-
A model-based learning controller with predictor augmentation for non-stationary conditions and time delay in water shooting
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1110-1117
-
Model-based coverage motion planning for industrial 3D shape inspection applications
IEEE International Conference on Automation Science and Engineering (CASE), pp. 1293-1300
-
On-line Bayesian regression mixture model for robot model learning
IEEE International Conference on Robotics and Automation (ICRA), pp. 6449-6454
-
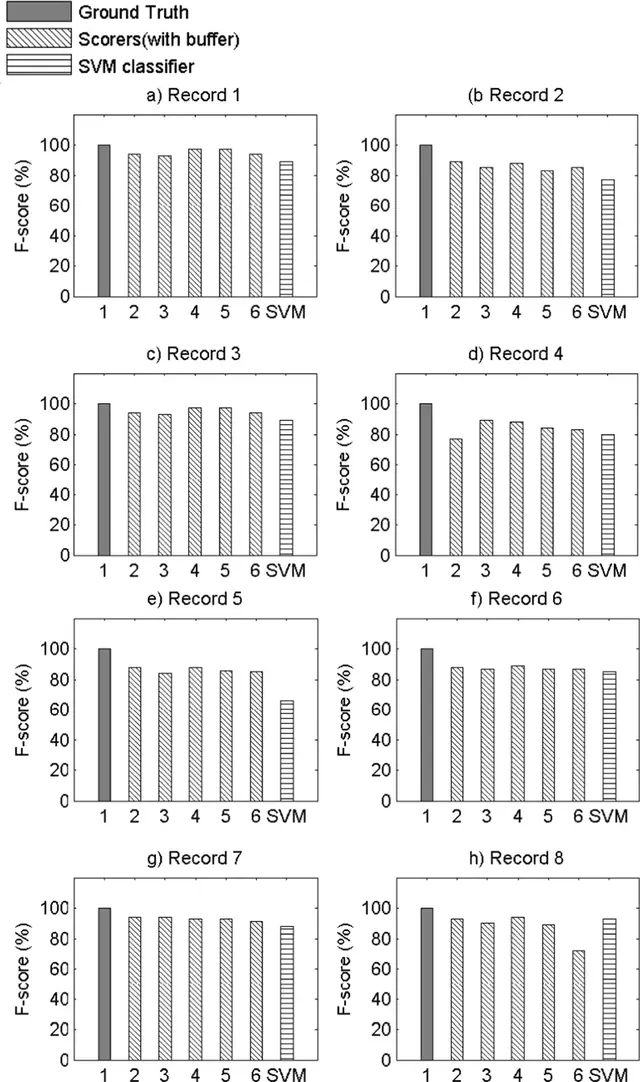
Support vector machines for automated snoring detection: proof-of-concept
Sleep and Breathing, vol. 21, pp. 119-133
-
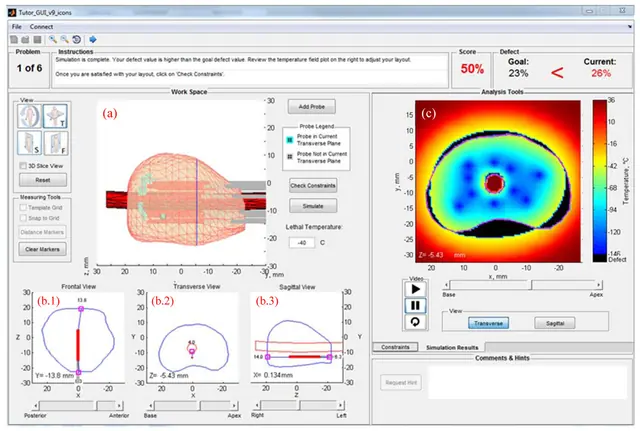
A computerized tutor prototype for prostate cryotherapy: key building blocks and system evaluation
Proceedings of SPIE (SPIE BiOS), vol. 10066, pp. 100660Z
-
GPU-Based Simulation of Ultrasound Imaging Artifacts for Cryosurgery Training
Technology in Cancer Research & Treatment, vol. 16, pp. 5-14
-
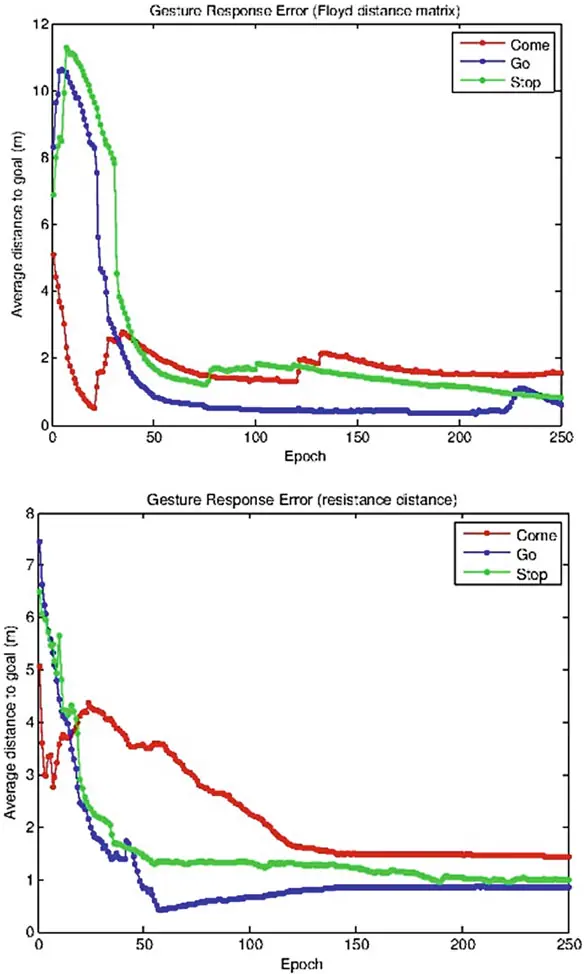
A Natural Interaction Interface for UAVs Using Intuitive Gesture Recognition
Advances in Intelligent Systems and Computing, pp. 387-398
-
An educational method for enhancing the ability to design innovative products
21st International Conference on Engineering Design (ICED17), pp. 049-058
-
An International Design Engineering School for Enhancing the Synthetic Thinking Ability
Journal of JSEE, vol. 65, pp. 5_59-5_67
-
An International Innovation Design School for Enhancing the Imagination to Design Future Products
Proceedings of the JSPE Semestrial Meeting (Japan Society for Precision Engineering)
2016
-
Simulation-Based Cryosurgery Training: Variable Insertion Depth Planning in Prostate Cryosurgery
Technology in Cancer Research & Treatment, vol. 15, pp. 805-814
-
Optimizing path for kinematically redundant robotic inspection system using Obstacle Based Probabilistic Roadmap and Genetic Algorithm
IEEE Region 10 Conference (TENCON), pp. 2716-2721
-
View planning for 3D shape reconstruction of buildings with unmanned aerial vehicles
International Conference on Control, Automation, Robotics and Vision (ICARCV), pp. 1-6
-
Sampling-based view planning for 3D visual coverage task with Unmanned Aerial Vehicle
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1808-1815
-
A Patient-Specific Flexible 3D Printed Orthopedic Model for Training and Teaching of Clubfoot Correction Surgery
3D Printing and Additive Manufacturing, vol. 3, pp. 98-105
-
Calibration of industry robots with consideration of loading effects using Product-Of-Exponential (POE) and Gaussian Process (GP)
IEEE International Conference on Robotics and Automation (ICRA), pp. 4380-4385
-
港湾荷役の自動化からロボット化へ (From Automation to Robotization in Port Cargo Handling)
Cargo Handling Japan (港湾荷役), vol. 61(3), pp. 303
-
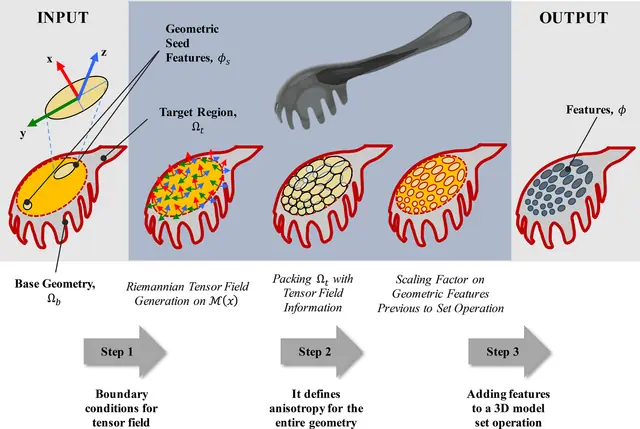
Automatic Generation of Anisotropic Patterns of Geometric Features for Industrial Design
Journal of Mechanical Design, vol. 138, art. 021403
-
Automated Generation of Repeated Geometric Patterns for Customized Additively Manufactured Personal Products
Procedia Manufacturing, vol. 5, pp. 944-957
2013
-
The travelling salesman problem with neighbourhoods: MINLP solution
Optimization Methods and Software, vol. 28, pp. 364-378
2011
-
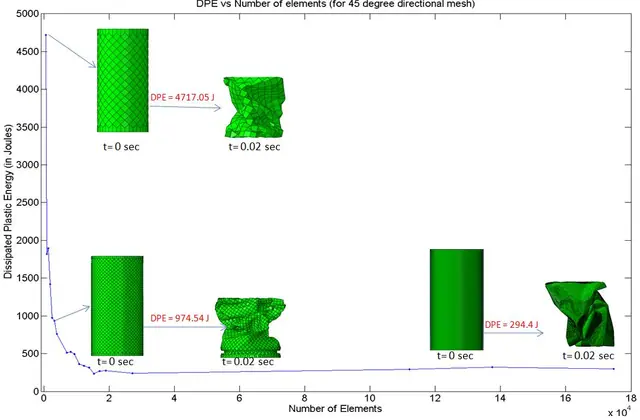
Current Issues and Trends in Meshing and Geometric Processing for Computational Engineering Analyses
Journal of Computing and Information Science in Engineering, vol. 11, art. 021008
2010
-
Unconstrained plastering—Hexahedral mesh generation via advancing‐front geometry decomposition
International Journal for Numerical Methods in Engineering, vol. 81, pp. 135-171
2007
-
An efficient numerical technique for bioheat simulations and its application to computerized cryosurgery planning
Computer Methods and Programs in Biomedicine, vol. 85, pp. 41-50
-
Sketch-Based 3D-Shape Creation for Industrial Styling Design
IEEE Computer Graphics and Applications, vol. 27, pp. 60-71
2006
-
Pen-based styling design of 3D geometry using concept sketches and template models
ACM Symposium on Solid and Physical Modeling (SPM), pp. 149-160
2005
-
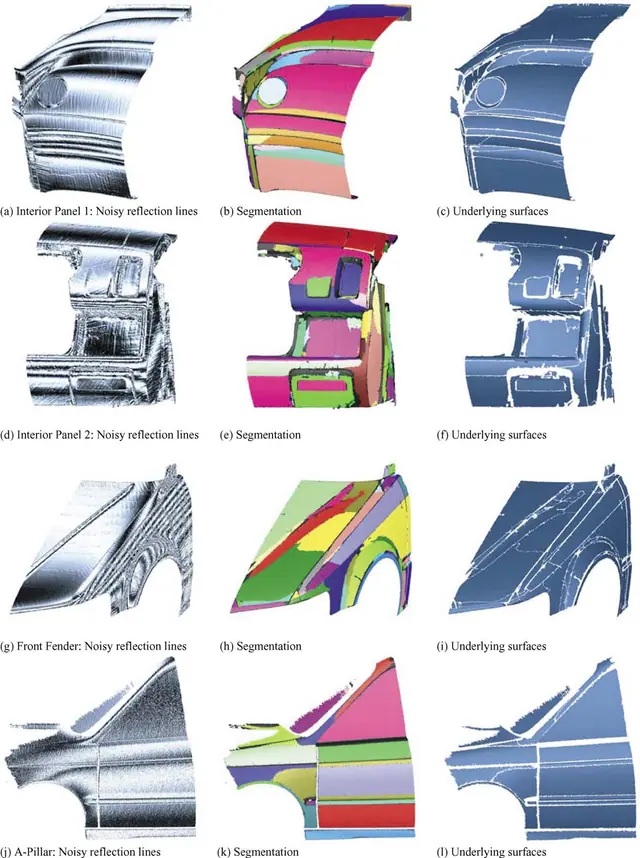
Surface mesh segmentation and smooth surface extraction through region growing
Computer Aided Geometric Design, vol. 22, pp. 771-792
-
Combining geometry and domain knowledge to interpret hand-drawn diagrams
Computers & Graphics, vol. 29, pp. 547-562
2003
-
Fully‐automated hex‐dominant mesh generation with directionality control via packing rectangular solid cells
International Journal for Numerical Methods in Engineering, vol. 57, pp. 2099-2129
-
Anisotropic tetrahedral meshing via bubble packing and advancing front
International Journal for Numerical Methods in Engineering, vol. 57, pp. 1923-1942
2002
-
A survey of computational approaches to three-dimensional layout problems
Computer-Aided Design, vol. 34, pp. 597-611
2000
-
Anisotropic Triangulation of Parametric Surfaces via Close Packing of Ellipsoids
International Journal of Computational Geometry & Applications, vol. 10, pp. 417-440
1998
-
Automatic triangular mesh generation of trimmed parametric surfaces for finite element analysis
Computer Aided Geometric Design, vol. 15, pp. 199-222
1995
-
Bubble mesh: automated triangular meshing of non-manifold geometry by sphere packing
ACM Symposium on Solid Modeling and Applications (SMA), pp. 409-419
No publications match these filters.