Abstract
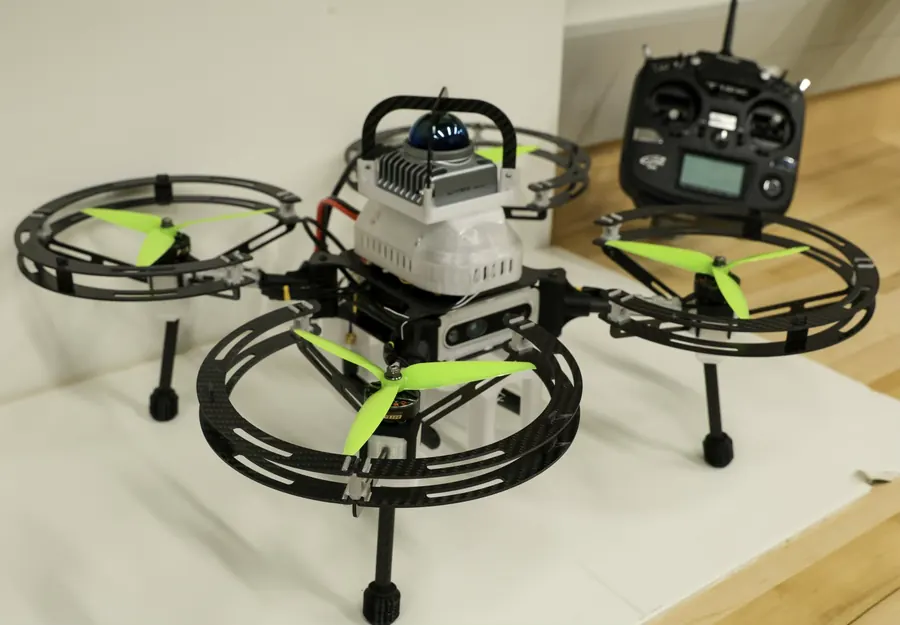
Small drones are an ideal tool for performing inspections within confined environments. However, due to their smaller mass, small drones are subject to greater deviations based on wind disturbances. The ability to mitigate wind disturbances for unmanned aerial vehicles (UAVs) is a field of research with many disparate existing solutions. Some require immense computational capacity while others do not guarantee explicit position control performance. The methodology proposed herein uses available onboard sensors and a shallow neural network that can select control system parameters based on a desired maximum flight error when subjected to a wind disturbance, thus providing an adaptive flight control without sacrificing flight performance. The results show that the proposed neural network can recommend parameters that improve the system performance.