PhD student
Xiaoyang Zhan
- Department
- Mechanical Engineering
- Program
- Ph.D.
- Graduation
- May 2028
- Autonomous Exploration
- Heterogeneous robot
- Semantic Mapping
Projects
Publications
7 papers with CERLAB.
- Pose-aware Legged Robot Semantic Exploration with Omnidirectional Perception in Confined Unknown Environments
arXiv preprint · 2026
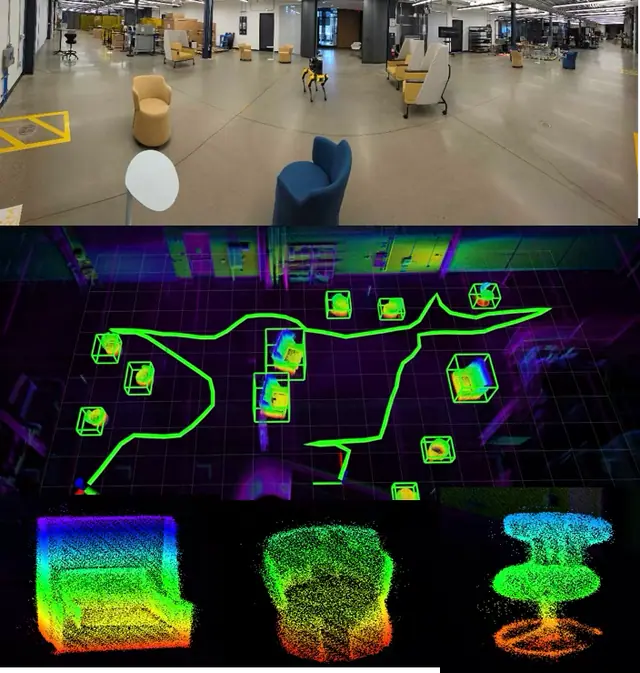
- Semantic Exploration and Dense Mapping of Complex Environments Using Ground Robot With Panoramic LiDAR-Camera Fusion
IEEE Robotics and Automation Letters · 2025
- Heuristic-based Incremental Probabilistic Roadmap for Efficient UAV Exploration in Dynamic Environments
IEEE International Conference on Robotics and Automation (ICRA) · 2024
- Onboard Dynamic-Object Detection and Tracking for Autonomous Robot Navigation With RGB-D Camera
IEEE Robotics and Automation Letters · 2024
- A real-time dynamic obstacle tracking and mapping system for UAV navigation and collision avoidance with an RGB-D camera
IEEE International Conference on Robotics and Automation (ICRA) · 2023
- A Vision-Based Autonomous UAV Inspection Framework for Unknown Tunnel Construction Sites With Dynamic Obstacles
IEEE Robotics and Automation Letters · 2023
- Vision-aided UAV Navigation and Dynamic Obstacle Avoidance using Gradient-based B-spline Trajectory Optimization
IEEE International Conference on Robotics and Automation (ICRA) · 2023